Research Projects

Beijing Institute of Technology

Data-Driven Computational Guidance for Aerial Vehicles (NSFC)

alt text 
  • Generalized prediction-correction framework for constrained computational guidance

  • Computational guidance using supervised learning

  • Computational guidance using reinforcement learning

  • Increasing learning efficiency and effectiveness in computational guidance

  • Safe learning in data-driven computational guidance

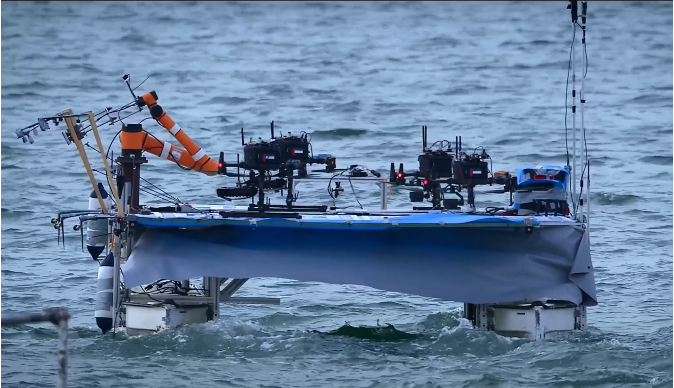
Operation of Heterogeneous UAV-USV System in a GNSS-denied Maritime Environment (with Khalifa University for MBZIRC 2024 Challenge)
alt text 
  • Collaborative navigation of UAV and USV without GNSS

  • Autonomous docking of USV with an uncooperative vessel

  • Autonomous landing and inspection of shipboard UAVs

  • Collaborative grasping and transporting object from target vessel

  • We are one of the best teams in the finals (Recording by MBZIRC Officials)

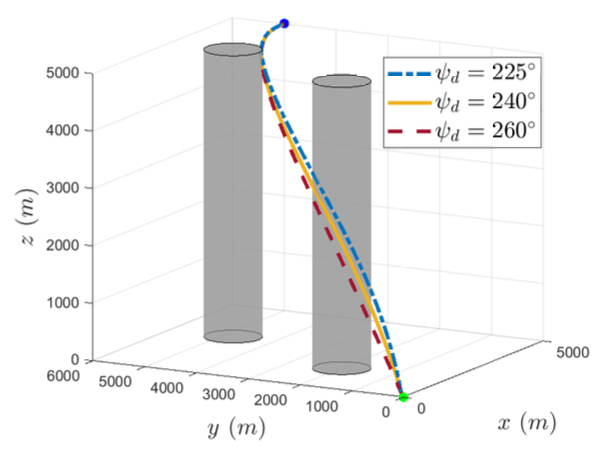
Efficient and Optimal Trajectory Generation for Aerial Vehicles (NSFC)
alt text 
  • Differential dynamic programming with flexible final time

  • Differential game differential dynamic programming with flexible final time

  • Stochastic differential dynamic programming

  • Differential dynamic programming with interior waypoint constraints

  • Algorithm validation through real flight test

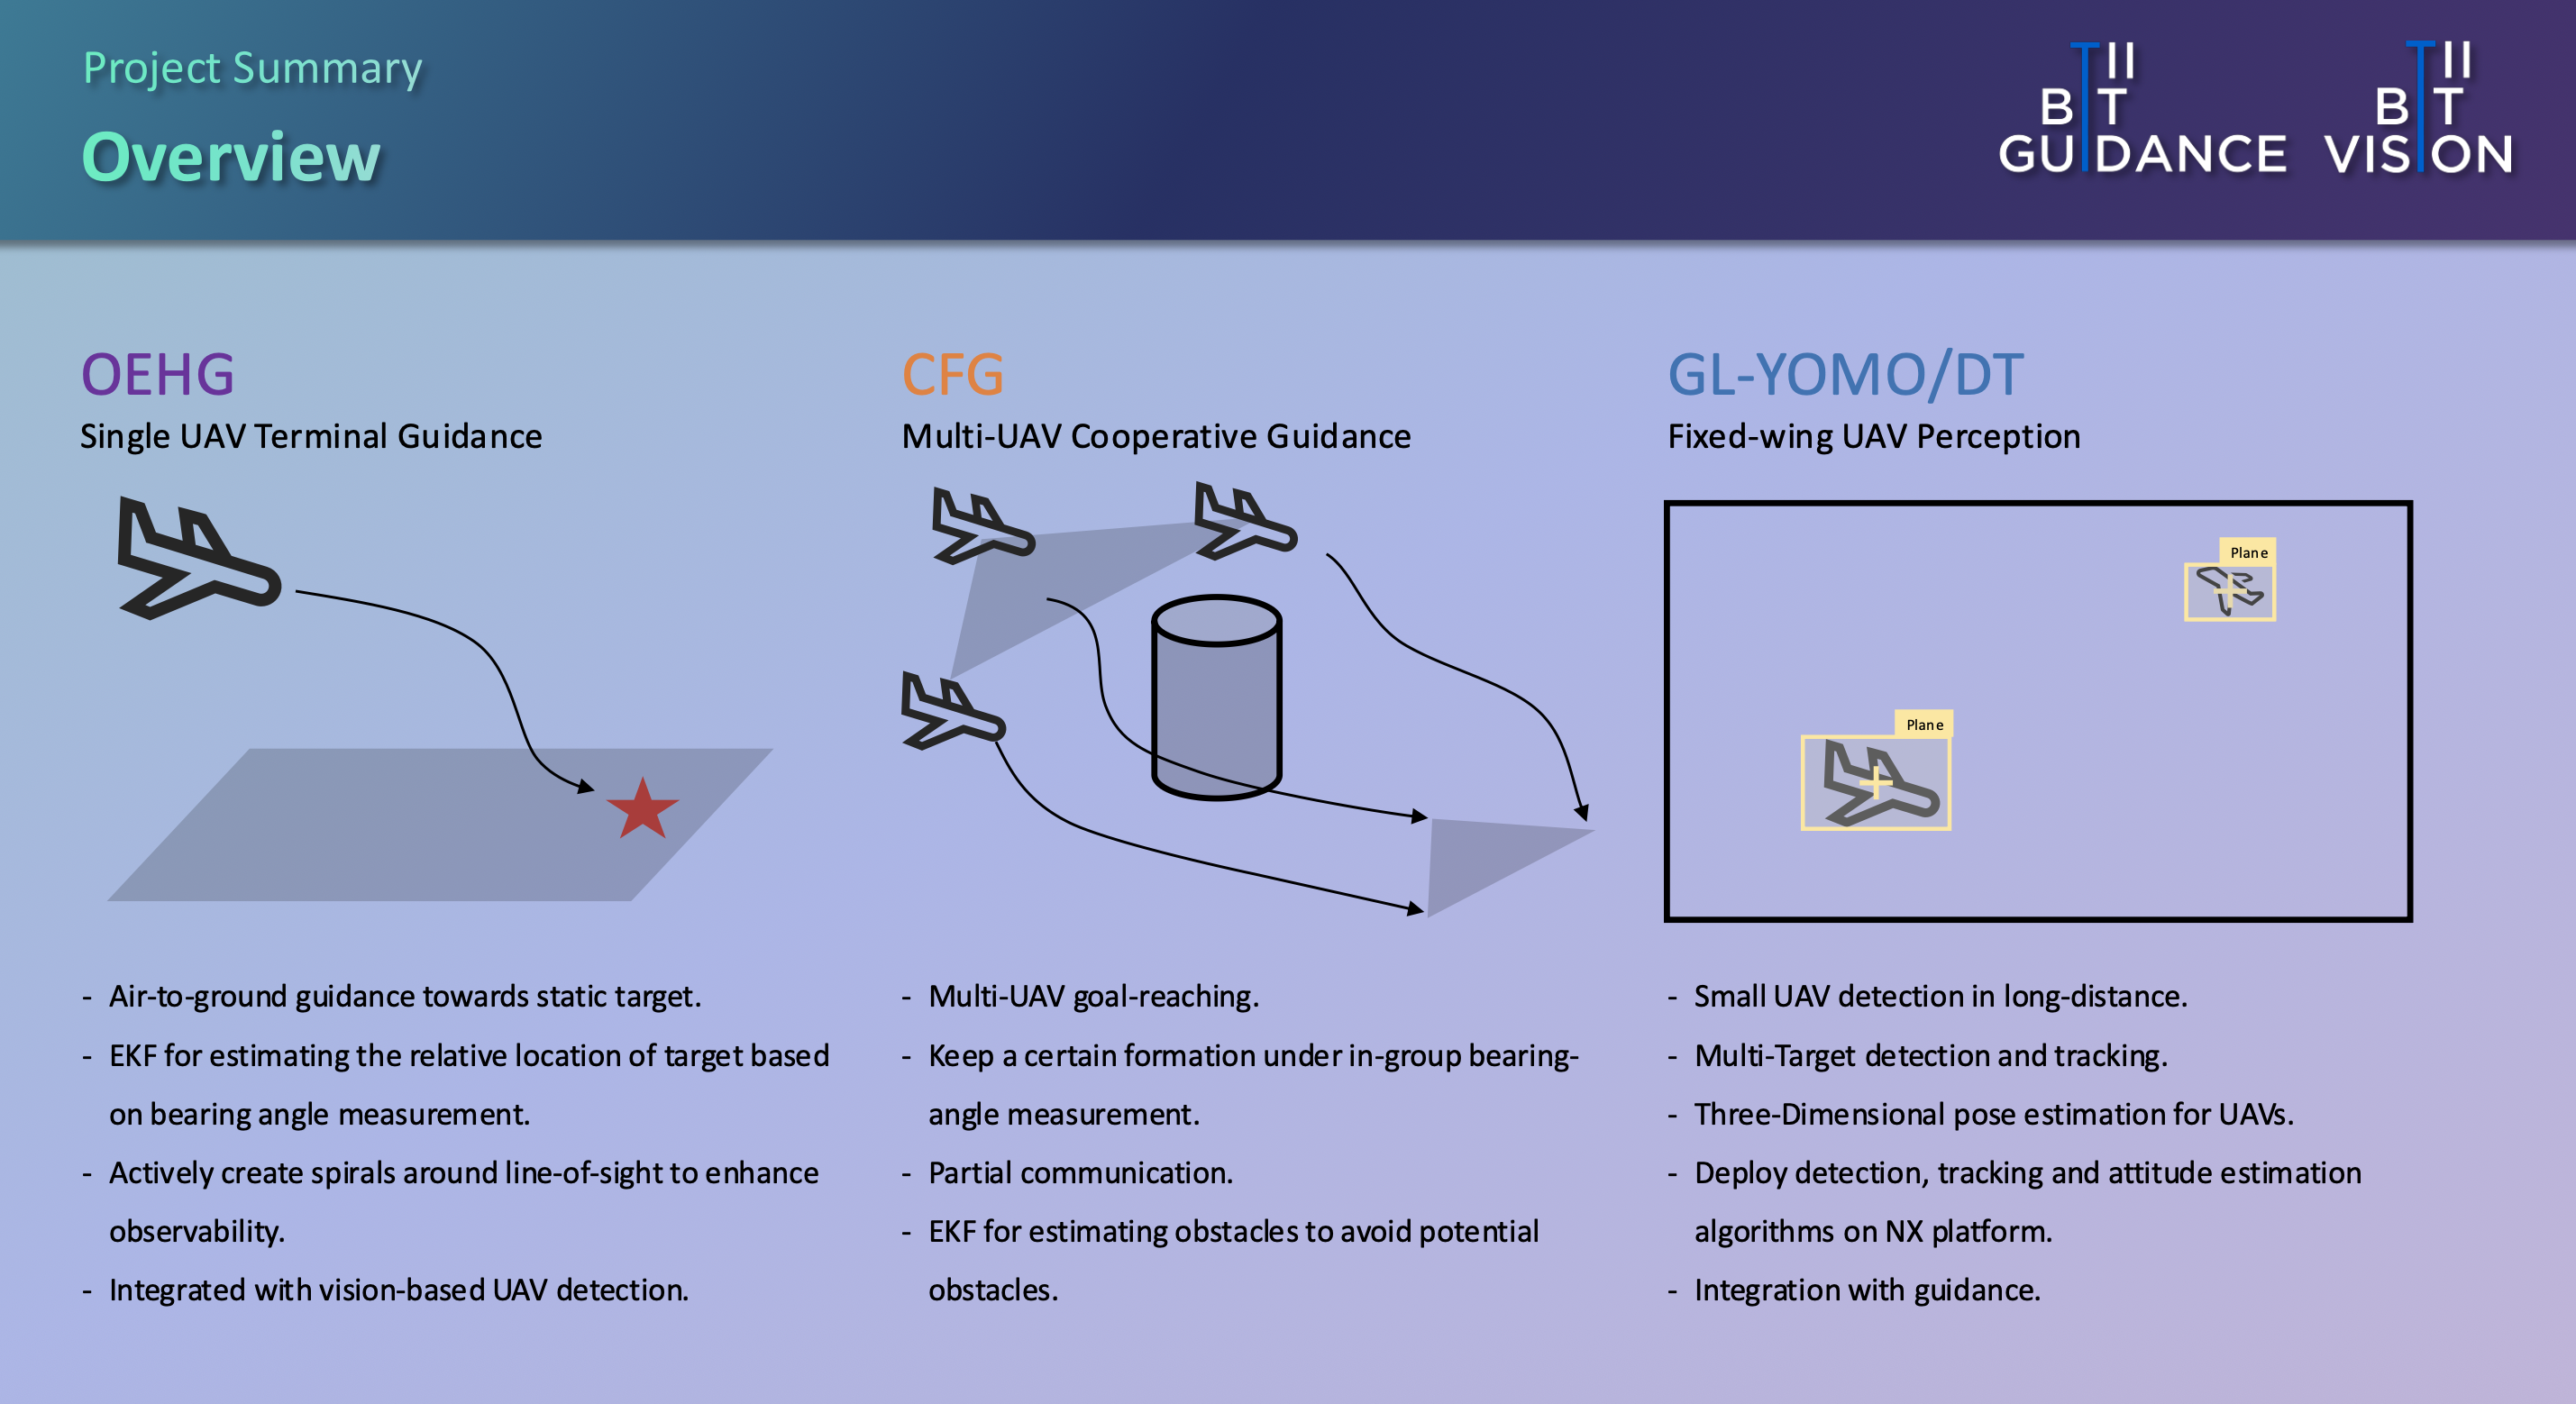
Bearing-only Guidance and Estimation of Fixed-wing UAV Platforms (Technology Innovation Institute)
alt text 
  • Optimal guidance for information maximization with bearing-only measurement

  • Formation control of fixed-wing UAVs with bearing-only measurement

  • Airborne UAVs detection and tracking (6D) using image sensors

  • Flight test of developed algorithms

Cranfield University

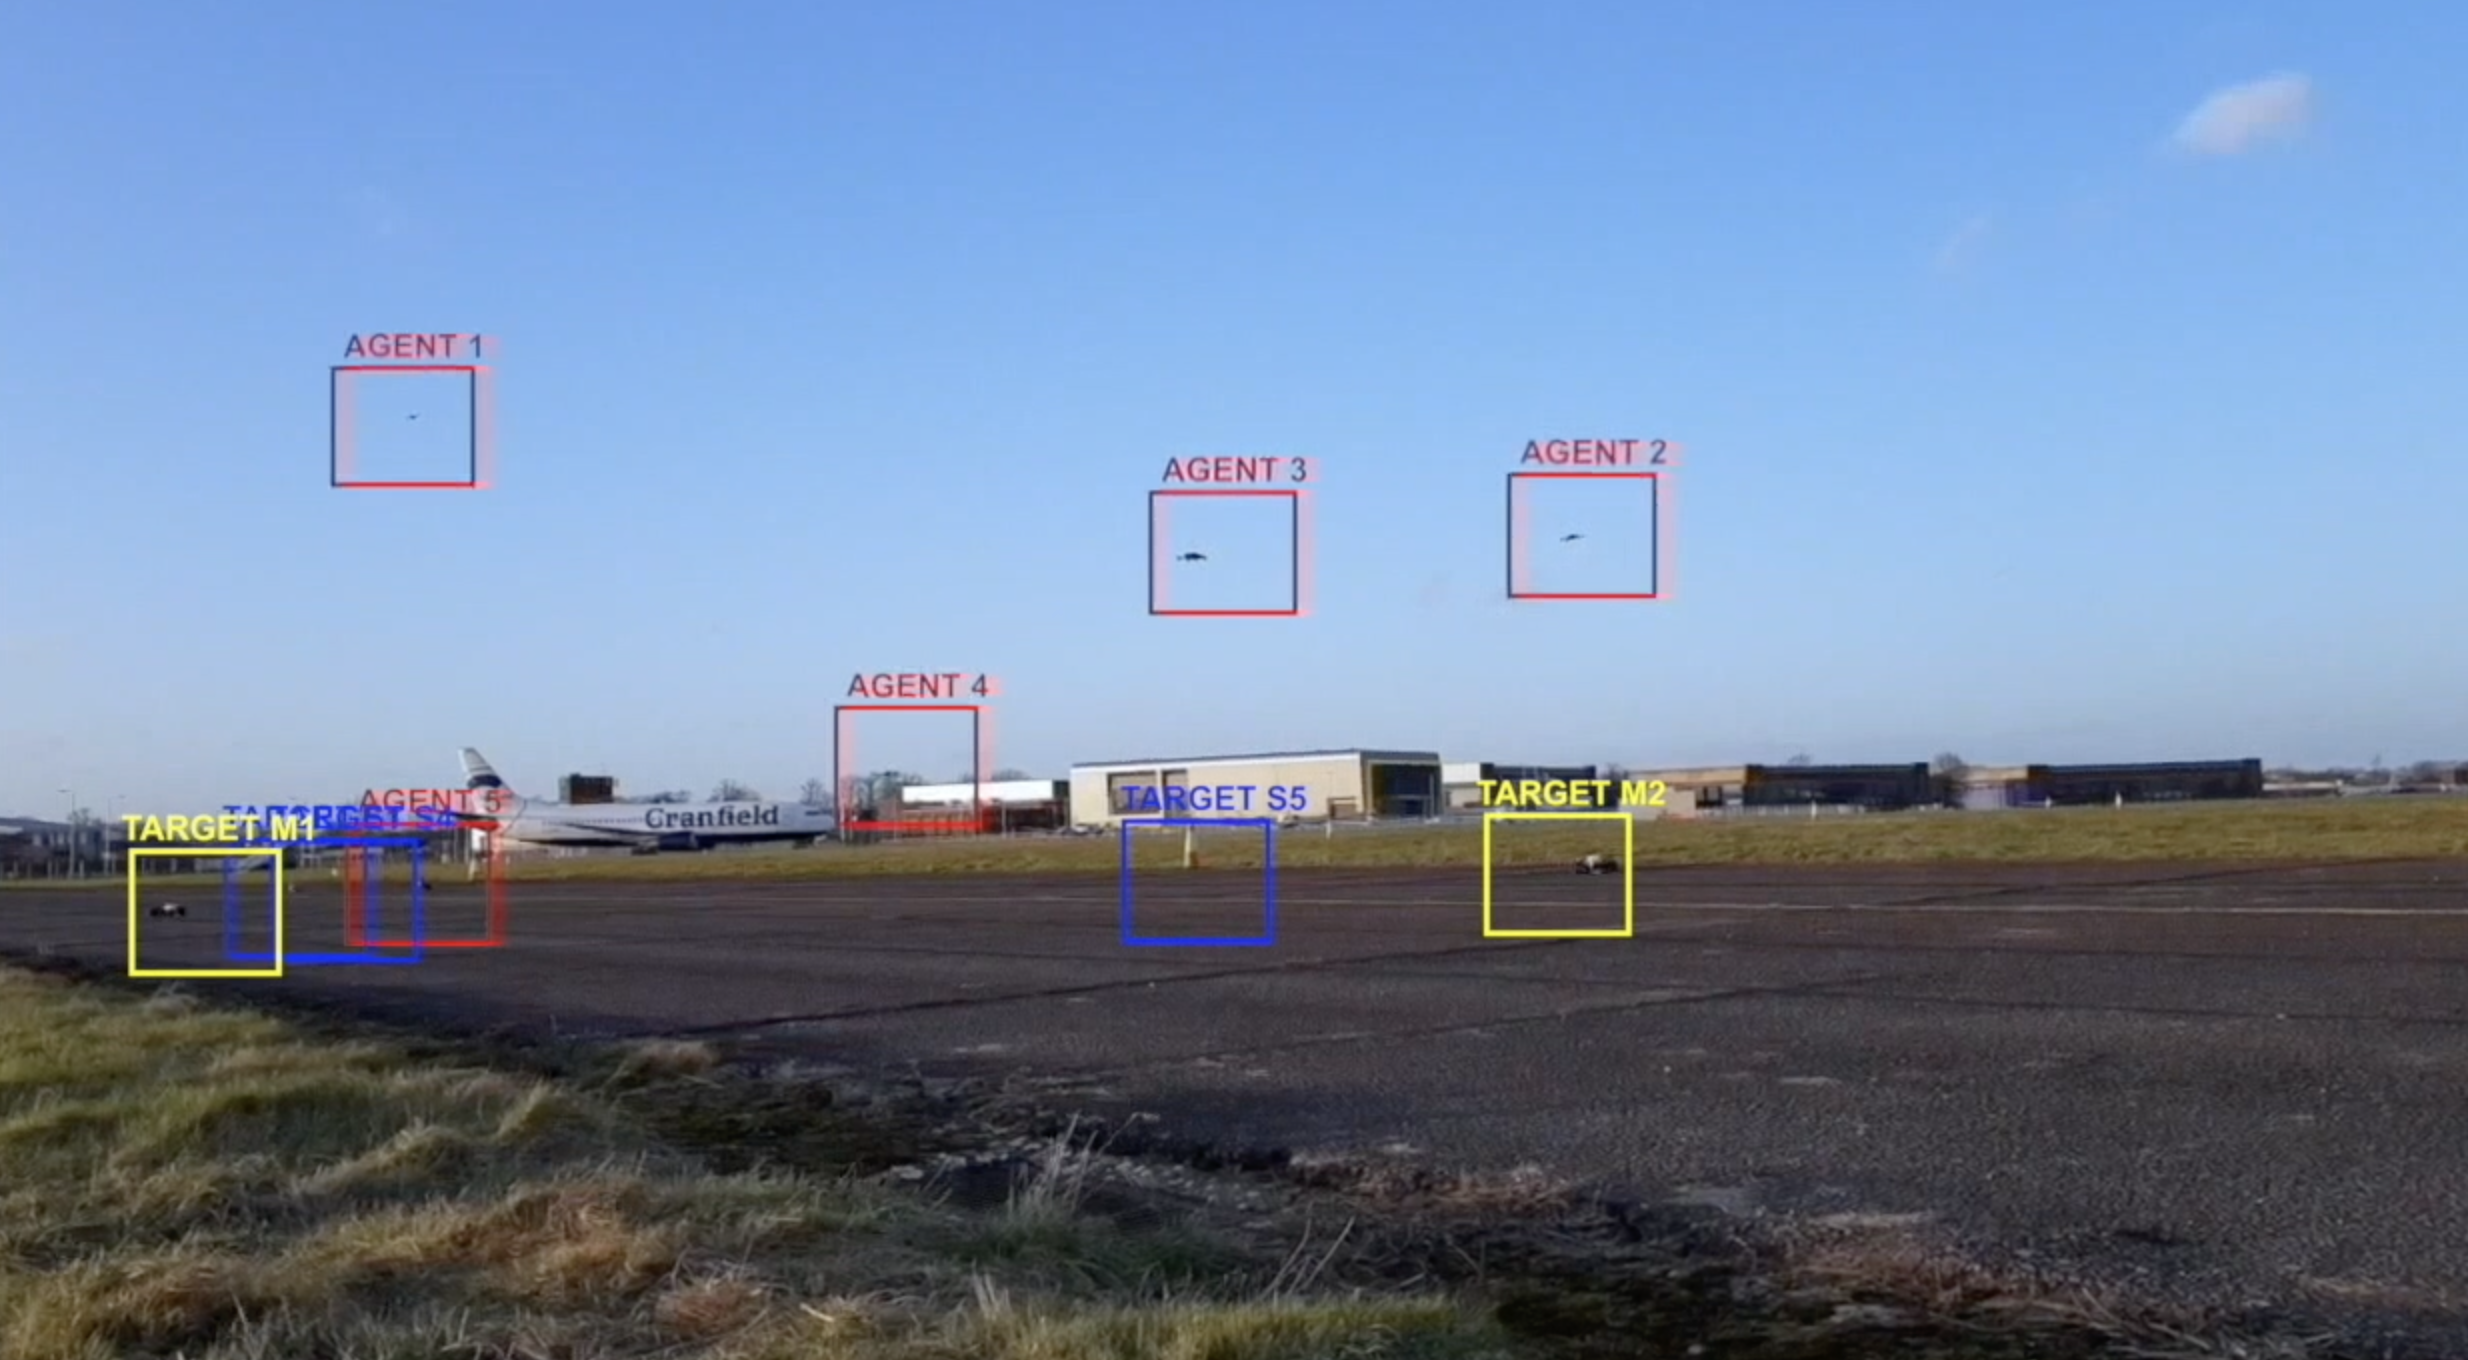
Airborne Behavior Monitoring of Ground Moving Targets
alt text 
  • Computationally efficient multi-target tracking with guaranteed performance

  • Distributed multi-target tracking algorithms for unmanned swarm heterogeneous systems

  • Target behavior analysis algorithm using a hybrid domain and data driven approach

  • Algorithm validation through real flight test

Reinforcement Learning in Trajectory Optimization and Flight Control
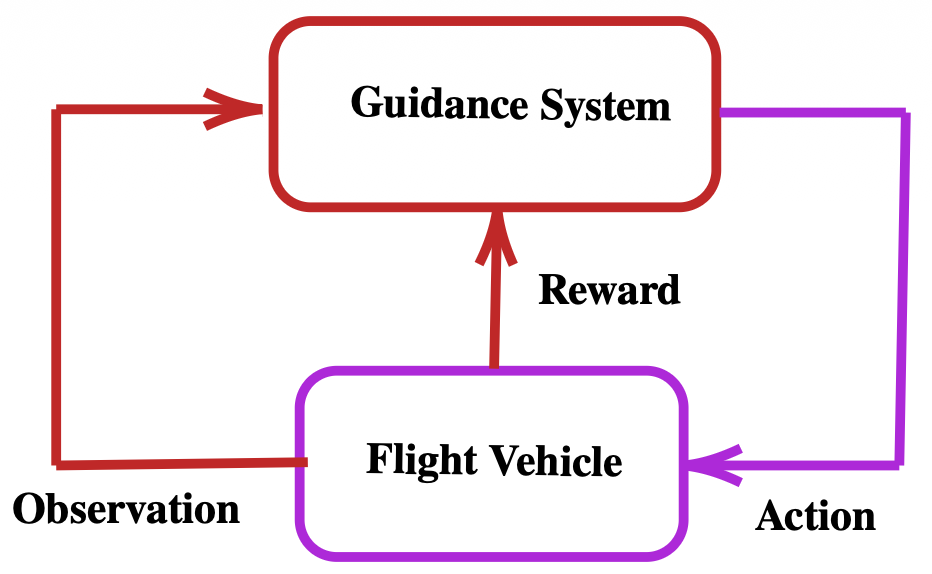
alt text 
  • Evaluate the performance of PPO and DDPG in trajectory optimization

  • Develop structured learning for flight control

  • Compare with conventional optimal guidance and gain scheduling control